# Make a Backup
if [[ ! -f /usr/share/swampd/config.json.original ]]
then
    cp /usr/share/swampd/config.json /usr/share/swampd/config.json.original
fi

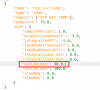
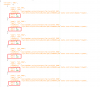
# Change the "setpoints" where it says "temps" (which is CPU, M2, OCP NIC...)
cat << 'EOF' > /usr/share/swampd/config.json
{
    "version": "R01",
    "sensors" : [
        {
            "name": "SYS_FAN",
            "type": "fan",
            "readPath": "/xyz/openbmc_project/sensors/fan_tach/SYS_FAN",
            "writePath": "/sys/devices/platform/ahb/ahb:apb/1e786000.pwm-tacho-controller/hwmon/**/pwm1",
            "min": 0,
            "max": 220
        },
        {
            "name": "SYS_FAN1",
            "type": "fan",
            "readPath": "/xyz/openbmc_project/sensors/fan_tach/SYS_FAN1",
            "writePath": "/sys/devices/platform/ahb/ahb:apb/1e786000.pwm-tacho-controller/hwmon/**/pwm2",
            "min": 0,
            "max": 220
        },
        {
            "name": "SYS_FAN2",
            "type": "fan",
            "readPath": "/xyz/openbmc_project/sensors/fan_tach/SYS_FAN2",
            "writePath": "/sys/devices/platform/ahb/ahb:apb/1e786000.pwm-tacho-controller/hwmon/**/pwm3",
            "min": 0,
            "max": 220
        },
        {
            "name": "SYS_FAN3",
            "type": "fan",
            "readPath": "/xyz/openbmc_project/sensors/fan_tach/SYS_FAN3",
            "writePath": "/sys/devices/platform/ahb/ahb:apb/1e786000.pwm-tacho-controller/hwmon/**/pwm4",
            "min": 0,
            "max": 220
        },
        {
            "name": "SYS_FAN4",
            "type": "fan",
            "readPath": "/xyz/openbmc_project/sensors/fan_tach/SYS_FAN4",
            "writePath": "/sys/devices/platform/ahb/ahb:apb/1e786000.pwm-tacho-controller/hwmon/**/pwm5",
            "min": 0,
            "max": 220
        },
        {
            "name": "SYS_FAN5",
            "type": "fan",
            "readPath": "/xyz/openbmc_project/sensors/fan_tach/SYS_FAN5",
            "writePath": "/sys/devices/platform/ahb/ahb:apb/1e786000.pwm-tacho-controller/hwmon/**/pwm6",
            "min": 0,
            "max": 220
        },
        {
            "name": "M2_TEMP",
            "type": "temp",
            "readPath": "/xyz/openbmc_project/sensors/temperature/M2_TEMP",
            "timeout": 0,
            "ignoreDbusMinMax": true
        },
        {
            "name": "OCP_NIC_TEMP",
            "type": "temp",
            "readPath": "/xyz/openbmc_project/sensors/temperature/OCP_NIC_TEMP",
            "timeout": 0,
            "ignoreDbusMinMax": true
        },
        {
            "name": "CPU_CORE_MOSFET",
            "type": "temp",
            "readPath": "/xyz/openbmc_project/sensors/temperature/CPU_CORE_MOSFET",
            "timeout": 0,
            "ignoreDbusMinMax": true
        },
        {
            "name": "CPU_SOC_MOSFET",
            "type": "temp",
            "readPath": "/xyz/openbmc_project/sensors/temperature/CPU_SOC_MOSFET",
            "timeout": 0,
            "ignoreDbusMinMax": true
        },
        {
            "name": "CPU_TEMP",
            "type": "temp",
            "readPath": "/xyz/openbmc_project/sensors/temperature/CPU_TEMP",
            "timeout": 0,
            "ignoreDbusMinMax": true
        },
        {
            "name": "DIMM_MOSFET_1",
            "type": "temp",
            "readPath": "/xyz/openbmc_project/sensors/temperature/DIMM_MOSFET_1",
            "timeout": 0,
            "ignoreDbusMinMax": true
        },
        {
            "name": "DIMM_MOSFET_2",
            "type": "temp",
            "readPath": "/xyz/openbmc_project/sensors/temperature/DIMM_MOSFET_2",
            "timeout": 0,
            "ignoreDbusMinMax": true
        },
        {
            "name": "PSU0_TEMP",
            "type": "temp",
            "readPath": "/xyz/openbmc_project/sensors/temperature/PSU0_TEMP",
            "timeout": 0,
            "ignoreDbusMinMax": true
        },
        {
            "name": "PSU1_TEMP",
            "type": "temp",
            "readPath": "/xyz/openbmc_project/sensors/temperature/PSU1_TEMP",
            "timeout": 0,
            "ignoreDbusMinMax": true
        },
        {
            "name": "SYS_AMB",
            "type": "temp",
            "readPath": "/xyz/openbmc_project/sensors/temperature/SYS_AMB",
            "timeout": 0,
            "ignoreDbusMinMax": true
        }
    ],
    "zones": [
        {
            "id": 1,
            "minThermalOutput": 10.0,
            "failsafePercent": 100.0,
            "setpoint": 80.0,
            "pids": [
                {
                    "name": "Fan0",
                    "type": "fan",
                    "inputs": ["SYS_FAN"],
                    "setpoint": 40.0,
                    "pid": {
                        "samplePeriod": 1.0,
                        "proportionalCoeff": 0.0,
                        "integralCoeff": 0.0,
                        "feedFwdOffsetCoeff": 0.0,
                        "feedFwdGainCoeff": 1.0,
                        "integralLimit_min": 0.0,
                        "integralLimit_max": 0.0,
                        "outLim_min": 0.0,
                        "outLim_max": 100.0,
                        "slewNeg": 0.0,
                        "slewPos": 0.0
                    }
                },
                {
                    "name": "Fan1",
                    "type": "fan",
                    "inputs": ["SYS_FAN1"],
                    "setpoint": 40.0,
                    "pid": {
                        "samplePeriod": 1.0,
                        "proportionalCoeff": 0.0,
                        "integralCoeff": 0.0,
                        "feedFwdOffsetCoeff": 0.0,
                        "feedFwdGainCoeff": 1.0,
                        "integralLimit_min": 0.0,
                        "integralLimit_max": 0.0,
                        "outLim_min": 0.0,
                        "outLim_max": 100.0,
                        "slewNeg": 0.0,
                        "slewPos": 0.0
                    }
                },
                {
                    "name": "Fan2",
                    "type": "fan",
                    "inputs": ["SYS_FAN2"],
                    "setpoint": 40.0,
                    "pid": {
                        "samplePeriod": 1.0,
                        "proportionalCoeff": 0.0,
                        "integralCoeff": 0.0,
                        "feedFwdOffsetCoeff": 0.0,
                        "feedFwdGainCoeff": 1.0,
                        "integralLimit_min": 0.0,
                        "integralLimit_max": 0.0,
                        "outLim_min": 0.0,
                        "outLim_max": 100.0,
                        "slewNeg": 0.0,
                        "slewPos": 0.0
                    }
                },
                {
                   "name": "Fan3",
                    "type": "fan",
                    "inputs": ["SYS_FAN3"],
                    "setpoint": 40.0,
                    "pid": {
                        "samplePeriod": 1.0,
                        "proportionalCoeff": 0.0,
                        "integralCoeff": 0.0,
                        "feedFwdOffsetCoeff": 0.0,
                        "feedFwdGainCoeff": 1.0,
                        "integralLimit_min": 0.0,
                        "integralLimit_max": 0.0,
                        "outLim_min": 0.0,
                        "outLim_max": 100.0,
                        "slewNeg": 0.0,
                        "slewPos": 0.0
                    }
                },
                {
                    "name": "Fan4",
                    "type": "fan",
                    "inputs": ["SYS_FAN4"],
                    "setpoint": 40.0,
                    "pid": {
                        "samplePeriod": 1.0,
                        "proportionalCoeff": 0.0,
                        "integralCoeff": 0.0,
                        "feedFwdOffsetCoeff": 0.0,
                        "feedFwdGainCoeff": 1.0,
                        "integralLimit_min": 0.0,
                        "integralLimit_max": 0.0,
                        "outLim_min": 0.0,
                        "outLim_max": 100.0,
                        "slewNeg": 0.0,
                        "slewPos": 0.0
                    }
                },
                {
                    "name": "Fan5",
                    "type": "fan",
                    "inputs": ["SYS_FAN5"],
                    "setpoint": 40.0,
                    "pid": {
                        "samplePeriod": 1.0,
                        "proportionalCoeff": 0.0,
                        "integralCoeff": 0.0,
                        "feedFwdOffsetCoeff": 0.0,
                        "feedFwdGainCoeff": 1.0,
                        "integralLimit_min": 0.0,
                        "integralLimit_max": 0.0,
                        "outLim_min": 0.0,
                        "outLim_max": 100.0,
                        "slewNeg": 0.0,
                        "slewPos": 0.0
                    }
                },
        {
            "name": "cpu_core",
            "type": "temp",
            "inputs": ["CPU_TEMP"],
            "setpoint": 80.0,
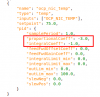
            "pid": {
                "samplePeriod": 1.0,
                "proportionalCoeff": -6.0,
                "integralCoeff": -0.1,
                "feedFwdOffsetCoeff": 0.0,
                "feedFwdGainCoeff": 0.0,
                "integralLimit_min": 0.0,
                "integralLimit_max": 0.0,
                "outLim_min": 0.0,
                "outLim_max": 100.0,
                "slewNeg": 0.0,
                "slewPos": 0.0
            }
        },
        {
            "name": "m2_temp",
            "type": "temp",
            "inputs": ["M2_TEMP"],
            "setpoint": 75.0,
            "pid": {
                "samplePeriod": 1.0,
                "proportionalCoeff": -6.0,
                "integralCoeff": -0.1,
                "feedFwdOffsetCoeff": 0.0,
                "feedFwdGainCoeff": 0.0,
                "integralLimit_min": 0.0,
                "integralLimit_max": 0.0,
                "outLim_min": 0.0,
                "outLim_max": 100.0,
                "slewNeg": 0.0,
                "slewPos": 0.0
            }
        },
        {
            "name": "ocp_nic_temp",
            "type": "temp",
            "inputs": ["OCP_NIC_TEMP"],
            "setpoint": 75.0,
            "pid": {
                "samplePeriod": 1.0,
                "proportionalCoeff": -3.0,
                "integralCoeff": -1.0,
                "feedFwdOffsetCoeff": 0.0,
                "feedFwdGainCoeff": 0.0,
                "integralLimit_min": 0.0,
                "integralLimit_max": 0.0,
                "outLim_min": 0.0,
                "outLim_max": 100.0,
                "slewNeg": 0.0,
                "slewPos": 0.0
            }
        }
            ]
        }
    ]
}
EOF

# Restart the service
sudo systemctl restart phosphor-pid-control.service